


Tianjin SWKS Technology & Development Co.,Ltd is one of the most reliable manufacturers and suppliers of custom pa66 industrial robot wrist cable clamp saddle in China. If you're going to buy bulk cheap custom pa66 industrial robot wrist cable clamp saddle, welcome to get quotation from our factory. Quality products and low price are available.
Custom PA66 Industrial Robot Wrist Cable Clamp Saddle
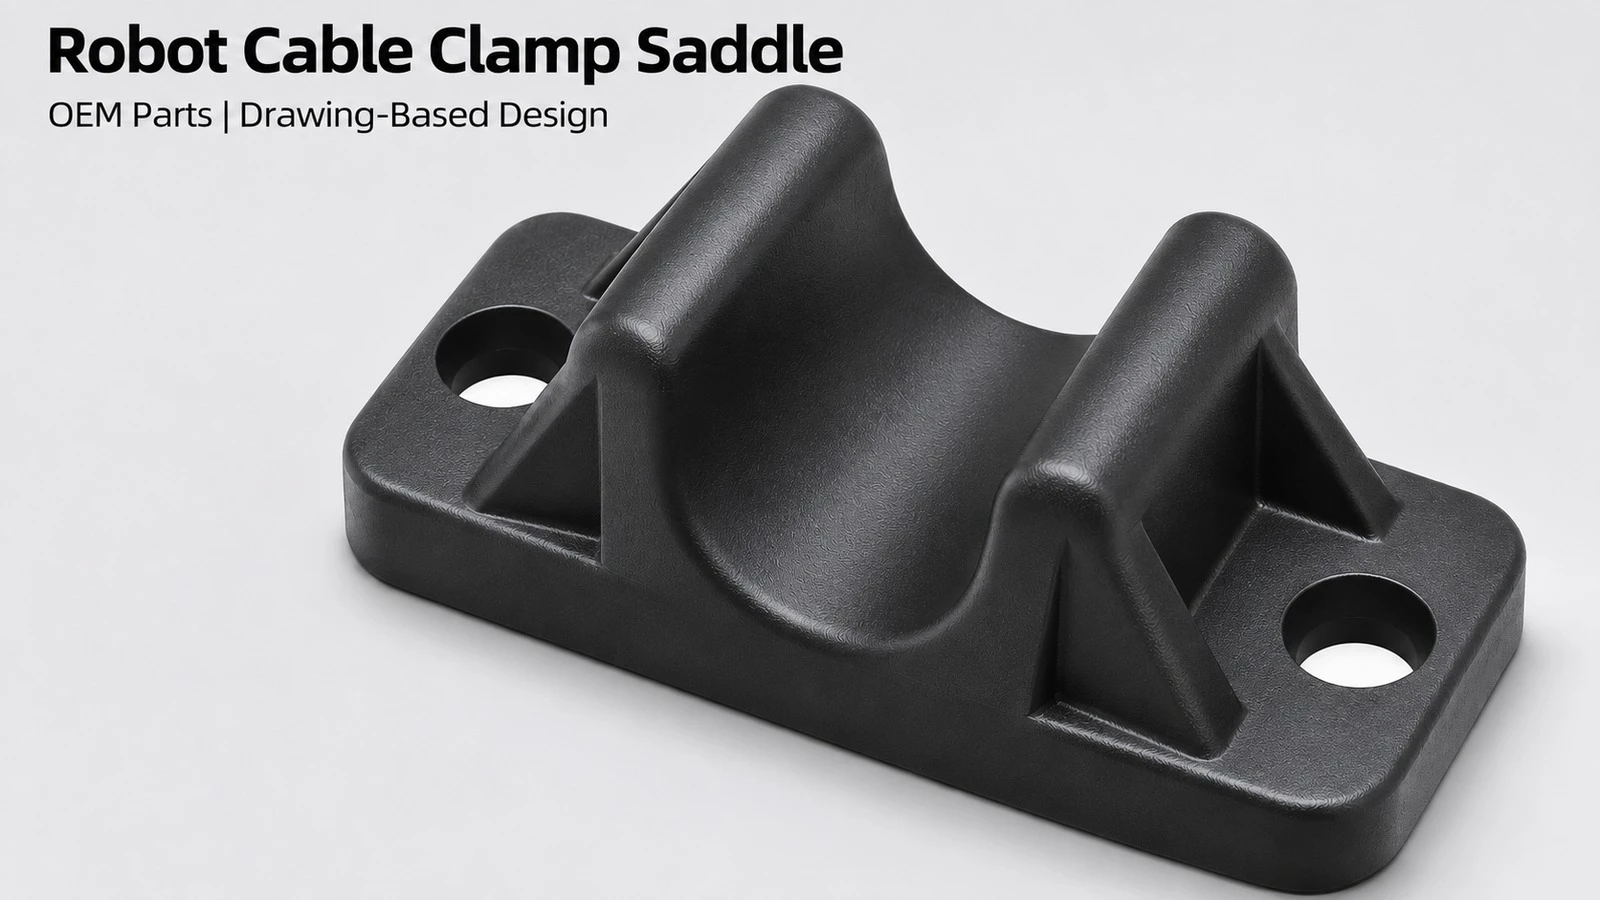
At a robot wrist, a cable bundle changes orientation repeatedly within a restricted space. This custom PA66 saddle provides a shaped support surface for a wrist-mounted cable clamp arrangement. It is intended for robot dress packs, automation end effectors and similar cable-management assemblies where the cradle, mounting points and nearby moving equipment need to be considered together.

Product Specification and Custom Options
| Material | PA66; specific grade agreed for the application |
|---|---|
| Process | Custom plastic injection molding |
| Intended application | Industrial robot wrists and robotic arm cable management |
| Dimensions and interfaces | According to approved customer drawings |
| Color and finish | Customized; images show a representative design |
| Drawing formats | STP, STEP, IGS and dimensioned drawings |
| Tooling and sampling | Drawing review, mold development and sample approval |
| Inspection | Functional dimensions and agreed appearance criteria |
| Order configuration | Quantity, packaging and documentation by quotation |
Function and Assembly Role
The saddle supports the bundle from below; an upper clamp, strap or other retaining component is defined by the assembly design. Its curved cradle can be adapted to the cable or protective conduit diameter, while flanged mounting areas connect it to the customer's bracket. Rounded contact edges and deliberate routing clearance help avoid concentrated contact at the edge of the support.
Material Selection
The specified PA66 formulation should be selected using the wrist environment, cable jacket material and fastening arrangement. Unfilled or reinforced grades may be evaluated depending on stiffness and contact requirements. Moisture conditioning affects nylon dimensions and should be included when establishing assembly fits. A grade designation alone does not confirm an outdoor, flame-retardant or electrical certification.
Critical Fit and Contact Design
Clamp geometry must balance retention with the cable manufacturer's permitted compression and bending conditions. The bundle should not be forced into a cradle that is too small, and the fastening arrangement should not turn the saddle into a sharp pinch point. Bolt positions, mounting orientation and clearance to the upper restraint can all be tailored to the customer's wrist interface.
Customization for the Equipment
Robot movement introduces concerns that a static fit check cannot reveal. Wrist rotation, tool changes and the full programmed motion envelope can change the cable's position relative to the saddle. A trial assembly should therefore check movement near adjacent housings, tool flanges and dress-pack components. The saddle supports routing; the complete cable-management system determines the permitted motion.
Sample Evaluation
Design development can include thicker mounting lands, local reinforcing ribs, locating shoulders or a replaceable support arrangement. Fastener seating and any compression limiters are agreed from the drawing rather than added without review. Gate and ejection positions should avoid critical cable-contact surfaces where a raised mark could interfere with the intended support function.
Inspection and Handling
Quality checks can cover cradle profile, hole spacing, mounting flatness and edge finish. Functional sampling with the selected conduit or cable bundle helps assess seating and access for assembly. The customer may also define repeated motion trials and inspection intervals appropriate to its robot program. Parts can be packed separately or with protective dividers to preserve the support surface.
Drawing Review and Production Preparation
Production preparation begins with a controlled drawing revision and a clear list of functional requirements. The CAD model establishes the overall form, while a dimensioned drawing identifies the datums, critical fits and acceptance limits. SWKS can review the proposed structure for molding, including wall transitions, draft, gating and ejection. Any proposed adjustment to a functional interface is discussed before tooling is finalized. Color, surface texture and marking requirements can be recorded in the same approval package.
After the tooling trial, sample parts provide a reference for dimensional inspection and customer assembly checks. The approved resin specification, sample condition and inspection method should be recorded together so that later production can be compared with the same baseline. Further information is available in our guide to injection molding tolerances and part performance and our overview of custom molded parts from CAD to production.
Information for a Custom Quotation
Please provide the 3D file, dimensioned drawing, mating component information and a short description of the operating conditions. Include the requested material, color, order quantity and estimated annual demand. If your project requires a specified resin grade, test report, traceability format or special packaging, identify it in the RFQ. These details allow the tooling proposal, sampling plan and production quotation to match the actual component requirements. Pricing, minimum order quantity and lead time are confirmed after the drawing review.
Welcome to send an inquiry for your robot cable clamp saddle. Send drawings and project requirements to amanda@tjswks.com or call 0086-15222707659.
Hot Tags: custom pa66 industrial robot wrist cable clamp saddle, China, suppliers, manufacturers, factory, bulk, cheap, low price, quotation, China Nylon Sprockets Suppliers, custom plastic injection parts, design injection molded plastic parts, injection plastic parts, packaging plastic injection parts, PP Plastic Injection Molding Automotive Parts


